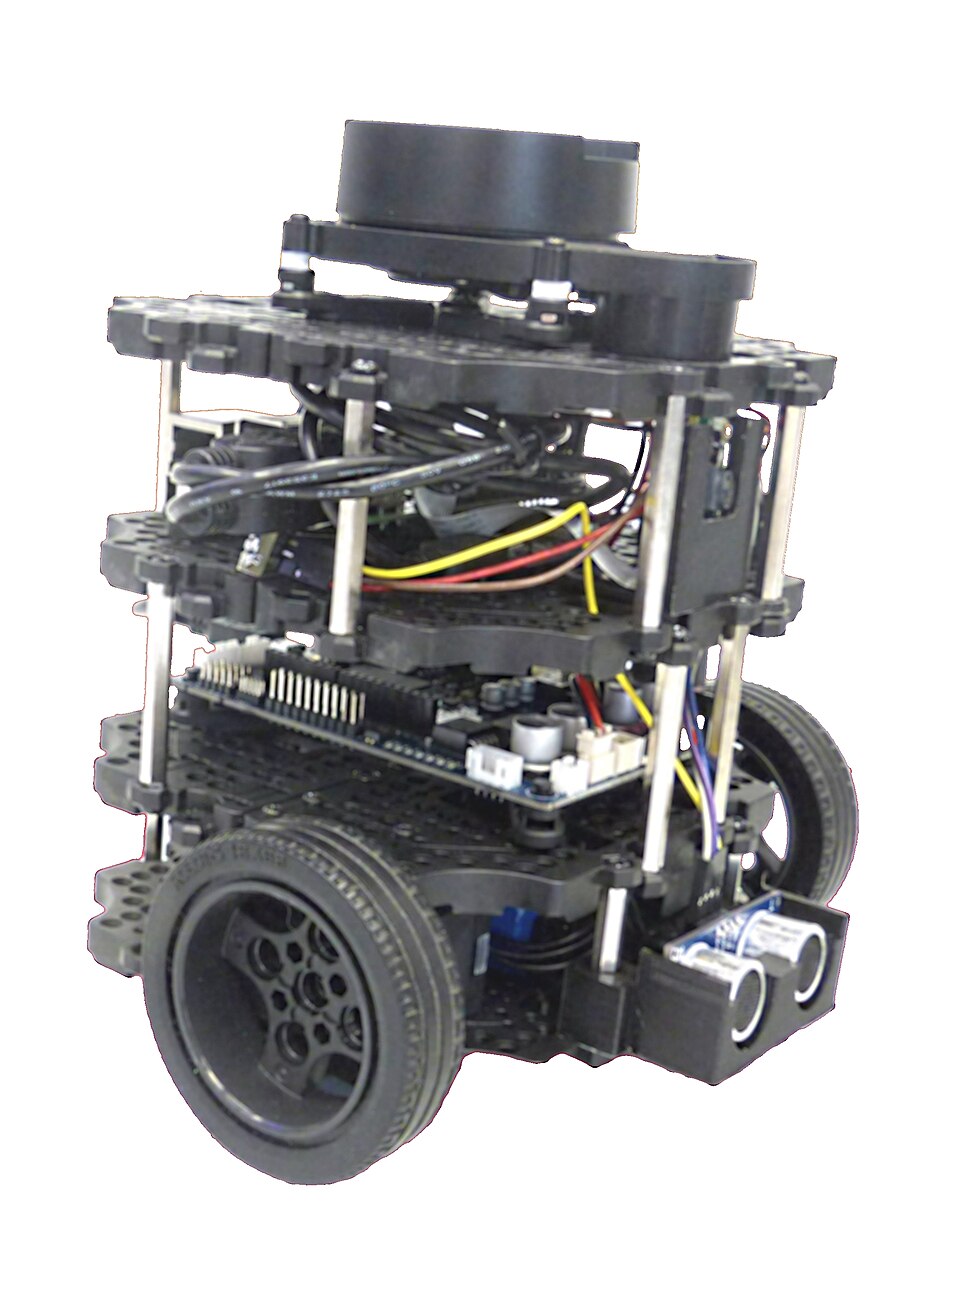
SLAM & autonomous navigation: photo by Kuscu0, CC BY-SA 4.0. Resized; display cropping may apply.
A PROJECT YOU CAN MAKE YOUR OWN
From first questions
to a working demo.
A mapping or navigation demo, evaluated trajectories, and a reproducible code repository.
This is a proposed learning path. The mentor, final project, start date, and weekly schedule will be confirmed before enrollment.
Your four-month journey
MONTH 01Frame the problem+
Define the navigation problem, explore sensor data, and establish a baseline.
MONTH 02Build your baseline+
Implement a mapping or localization component and measure performance.
MONTH 03Experiment & improve+
Test challenging trajectories and investigate drift or tracking failures.
MONTH 04Demonstrate & explain+
Present a reproducible navigation demo and defend your technical choices.
What to bring
Python or C++, basic linear algebra, and an interest in autonomous systems.
Plan for 4–6 hours of independent and team work each week, alongside your one-hour mentor meeting. The pilot is online, using public data and simulation.
Tools you'll work with
Python / C++ · ROS 2 · Simulation
What you'll take away
- A documented team project and your individual contribution
- A final demo and technical write-up
- Direct feedback and an individual assessment
- Opportunity to request a performance-based reference